|
|
|
last edited 13 years ago by Bill Page |
Edit detail for SandBox Quaternion Algebra is Frobenius in Many Ways revision 4 of 32
| 1 2 3 4 5 6 7 8 9 10 11 12 13 14 15 16 17 18 19 20 21 22 23 24 25 26 27 28 29 30 31 32 | ||
|
Editor: Bill Page
Time: 2011/04/19 11:49:27 GMT-7 |
||
| Note: Caley-Dickson split-quaternion | ||
changed:
-4-dimensional vector space representing Quaternion algebra
-
Quaternion Algebra Is Frobenius In Many Ways

Linear operators over a 4-dimensional vector space representing quaternion algebra

Ref:

- http://arxiv.org/abs/1103.5113

  $S_3$-permuted Frobenius Algebras

  *Zbigniew Oziewicz (UNAM), Gregory Peter Wene (UTSA)*

- http://mat.uab.es/~kock/TQFT.html

  Frobenius algebras and 2D topological quantum field theories

  *Joachim Kock*

- http://en.wikipedia.org/wiki/Frobenius_algebra

We need the Axiom LinearOperator library.
\begin{axiom}
)library MONAL PROP LIN CALEY
\end{axiom}

Use the following macros for convenient notation
\begin{axiom}
-- summation
macro Σ(x)==reduce(+,x)
macro ΣΞ(x,i)==reduce(+,[x for i in 1..dim])
-- list
macro Ξ(f,i)==[f for i in 1..dim]
\end{axiom}

𝐋 is the domain of 4-dimensional linear operators over the domain of rational functions ℚ (Expression Integer), i.e. ratio of polynomials with integer coefficients.

changed:
-T := CartesianTensor(1,dim,EXPR INT)
-X:List T := [unravel [(i=j => 1;0) for j in 1..dim] for i in 1..dim]
-X(1),X(2)
-\end{axiom}
-
-Generate structure constants for Quaternion Algebra
-\begin{axiom}
-B:=map(x+->quatern(x.1,x.2,x.3,x.4),1$SQMATRIX(4,FRAC INT)::List List FRAC INT)
-M:=matrix [[B.i*B.j for j in 1..4] for i in 1..4]
-S(y)==map(x+->(x*inv(y)=1 or x*inv(y)=-1 => x*inv(y);0),M)
-Yg:T:=unravel concat concat(map(S,B)::List List List FRAC POLY INT)
-\end{axiom}
macro ℒ == List
macro ℂ == CaleyDickson
macro ℚ == Expression Integer
𝐋 := LinearOperator(dim, OVAR [], ℚ)
𝐞:ℒ 𝐋      := basisVectors()
𝐝:ℒ 𝐋      := basisForms()
o:𝐋:=1     -- identity for product
I:𝐋:=[1]   -- identity for composition
X:𝐋:=[2,1] -- twist
\end{axiom}

Now generate structure constants for Quaternion Algebra

The basis consists of the real and imaginary units. We use quaternion multiplication to form the "multiplication table" as a matrix. Then the structure constants can be obtained by dividing each matrix entry by the list of basis vectors.
\begin{axiom}
-- Also split-complex via Caley-Dickson parameter (p0 = -1)
q0:=subscript('q,[0])
q1:=subscript('q,[1])
QQ := ℂ(ℂ(ℚ,'i,q0),'j,q1)
-- Basis: Each B.i is a quaternion number
B:ℒ QQ := map(x +-> hyper x,1$SQMATRIX(dim,ℚ)::ℒ ℒ ℚ)
-- Multiplication table:
M:Matrix QQ := matrix Ξ(Ξ(B.i*B.j,i),j)
-- Function to divide the matrix entries by a basis element
S(y) == map(x +-> real real(x/y),M)
-- The result is a nested list
ѕ :=map(S,B)::ℒ ℒ ℒ ℚ
-- structure constants form a tensor operator
Y := ΣΞ(ΣΞ(ΣΞ(ѕ(i)(j)(k)*𝐞.i*𝐝.j*𝐝.k,i),j),k)
arity Y
matrix Ξ(Ξ((𝐞.i*𝐞.j)/Y,i),j)
\end{axiom}

changed:
-U:T := unravel(concat
-  [[script(u,[[],[j,i]])
-    for i in 1..dim]
-      for j in 1..dim]
-        )
-\end{axiom}
U:=inp([inp([script(u,[[j,i],[]]) for i in 1..dim])$𝐋 for j in 1..dim])$𝐋
\end{axiom}


changed:
-  In other words, if the (3,0)-tensor::
-
-    i  j  k   i  j  k   i  j  k
-     \ | /     \/  /     \  \/
-      \|/   =   \ /   -   \ /
-       0         0         0
  In other words, if the (3,0)-tensor:
$$
\scalebox{1} % Change this value to rescale the drawing.
{
\begin{pspicture}(0,-0.92)(4.82,0.92)
\psbezier[linewidth=0.04](2.2,0.9)(2.2,0.1)(2.6,0.1)(2.6,0.9)
\psline[linewidth=0.04cm](2.4,0.3)(2.4,-0.1)
\psbezier[linewidth=0.04](2.4,-0.1)(2.4,-0.9)(3.0,-0.9)(3.0,-0.1)
\psline[linewidth=0.04cm](3.0,-0.1)(3.0,0.9)
\psbezier[linewidth=0.04](4.8,0.9)(4.8,0.1)(4.4,0.1)(4.4,0.9)
\psline[linewidth=0.04cm](4.6,0.3)(4.6,-0.1)
\psbezier[linewidth=0.04](4.6,-0.1)(4.6,-0.9)(4.0,-0.9)(4.0,-0.1)
\psline[linewidth=0.04cm](4.0,-0.1)(4.0,0.9)
\usefont{T1}{ptm}{m}{n}
\rput(3.4948437,0.205){-}
\psline[linewidth=0.04cm](0.6,-0.7)(0.6,0.9)
\psbezier[linewidth=0.04](0.0,-0.1)(0.0,-0.9)(1.2,-0.9)(1.2,-0.1)
\psline[linewidth=0.04cm](0.0,-0.1)(0.0,0.9)
\psline[linewidth=0.04cm](1.2,-0.1)(1.2,0.9)
\usefont{T1}{ptm}{m}{n}
\rput(1.6948438,0.205){=}
\end{pspicture}
}
$$

changed:
-\begin{axiom}
-ω := reindex(reindex(U,[2,1])*reindex(Yg,[1,3,2]),[3,2,1])-U*Yg
-\end{axiom}
Using the LinearOperator domain in Axiom and some carefully chosen symbols we can easily enter expressions that are both readable and interpreted by Axiom as "graphical calculus" diagrams describing complex products and compositions of linear operators.

\begin{axiom}

ω:𝐋 :=
     o    Y I      /
     o     U       -
     o    I Y      /
     o     U       o

\end{axiom}

Note: The only purpose of the o symbols on the left above is to serve as a constant left-side margin as required by Axiom. The symbols on the right describe the relation between row.


changed:
-  is called *pre-Frobenius*.
  is called a [Frobenius Algebra].

added:


changed:
-J := jacobian(ravel ω,concat(map(variables,ravel U))::List Symbol);
-uu := transpose matrix [concat(map(variables,ravel(U)))::List Symbol];
-J::OutputForm * uu::OutputForm = 0
-nrows(J)
-ncols(J)
-\end{axiom}
J := jacobian(ravel ω,concat map(variables,ravel U)::ℒ Symbol);
u := transpose matrix [concat map(variables,ravel U)::ℒ Symbol];
J::OutputForm * u::OutputForm = 0
nrows(J),ncols(J)
\end{axiom}


changed:
-\begin{axiom}
-NJ:=nullSpace(J)
-SS:=map((x,y)+->x=y,concat map(variables,ravel U),
-  entries reduce(+,[p[i]*NJ.i for i in 1..#NJ]))
-Ug:T := unravel(map(x+->subst(x,SS),ravel U))
-\end{axiom}

\begin{axiom}
Ñ:=nullSpace(J)
ℰ:=map((x,y)+->x=y,concat map(variables,ravel U),
  entries Σ[p[i]*Ñ.i for i in 1..#Ñ])
Ų := map(x+->subst(x,ℰ),U)$𝐋
\end{axiom}

changed:
-test(unravel(map(x+->subst(x,SS),ravel ω))$T=0*ω)
-\end{axiom}
test(map(x+->subst(x,ℰ),ω)$𝐋=0*ω)
\end{axiom}

changed:
-Ud:DMP([p[i] for i in 1..#NJ],INT) := determinant [[Ug[i,j] for j in 1..dim] for i in 1..dim]
-factor Ud
-\end{axiom}
Ů:=determinant [[retract((𝐞.i * 𝐞.j)/Ų) for j in 1..dim] for i in 1..dim]
factor Ů
\end{axiom}

changed:
-\begin{axiom}
-Ωg:T:=unravel concat(transpose(1/Ud*adjoint([[Ug[i,j] for j in 1..dim] for i in 1..dim]).adjMat)::List List FRAC POLY INT)
-\end{axiom}
-<center><pre>
-dimension
-Ω
-U
-</pre></center>
-\begin{axiom}
-contract(contract(Ωg,1,Ug,1),1,2)
-\end{axiom}

\begin{axiom}
Ω:𝐋:=unravel((0/2)$Prop,concat(transpose(1/Ů*adjoint([[retract((𝐞.i * 𝐞.j)/Ų)
  for j in 1..dim] for i in 1..dim]).adjMat)::ℒ ℒ ℚ))
\end{axiom}

Check dimension
\begin{axiom}

d:𝐋:=
    o   Ω    /
    o   Ų    o

\end{axiom}

changed:
-  Co-multiplication
-\begin{axiom}
-λg:=reindex(contract(contract(Ug*Yg,1,Ωg,1),1,Ωg,1),[2,3,1]);
--- just for display
-reindex(λg,[3,1,2])
-\end{axiom}
-<center><pre>
-i
-λ=Ω
-</pre></center>
-\begin{axiom}
-test(λg*X(1)=Ωg)
-\end{axiom}
  Co-algebra::

    λ:𝐋 :=
         o    Ω Ω  I    /
         o   I Y I I    /
         o   I  X  I    /
         o   I I  Ų     o
    --test

Why aren't these the same??

\begin{axiom}

λ:𝐋 :=
     o    I Ω     /
     o     Y I    o

λ2:𝐋 :=
     o     Ω I    /
     o    I Y     o

λ - λ2

\end{axiom}

i = Unit of the algebra
\begin{axiom}
i:=𝐞.1
test
     o    i     /
     o    λ     =    Ω

\end{axiom}

changed:
-ιg:=X(1)*Ug

ι:𝐋:=
    o    i I    /
    o     Ų    o


changed:
-test(ιg * Yg = Ug)
-\end{axiom}
test
   o     Y     /
   o     ι     o  = Ų

\end{axiom}

changed:
-Ug0:T:=unravel eval(ravel Ug,[p[1]=1,p[2]=0,p[3]=0,p[4]=1])
-Ωg0:T:=unravel eval(ravel Ωg,[p[1]=1,p[2]=0,p[3]=0,p[4]=1])
-λg0:T:=unravel eval(ravel λg,[p[1]=1,p[2]=0,p[3]=0,p[4]=1]);
-reindex(λg0,[3,1,2])
-\end{axiom}
-
-$S_3$-permuted Frobenius Algebras
-
-    Zbigniew Oziewicz, Gregory Peter Wene
-    (26 Mar 2011)
-    http://arxiv.org/abs/1103.5113
-
-\begin{axiom}
-test( Yg = reindex(reindex(  reindex(Ug*Yg,[1,2,3]),  [2,3,1])*Ωg,[3,1,2]) )
-
-Yg213 := reindex(reindex(  reindex(Ug*Yg,[2,1,3]),  [2,3,1])*Ωg,[3,1,2]);
-ω213  := reindex(reindex(U,[2,1])*reindex(Yg213,[1,3,2]),[3,2,1])-U*Yg213;
-J213  := jacobian(ravel ω213,concat(map(variables,ravel U))::List Symbol);
-NJ213 := nullSpace(J213)
-
--- opposite algebra
-Yg132 := reindex(reindex(  reindex(Ug*Yg,[1,3,2]),  [2,3,1])*Ωg,[3,1,2]);
-ω132  := reindex(reindex(U,[2,1])*reindex(Yg132,[1,3,2]),[3,2,1])-U*Yg132;
-J132  := jacobian(ravel ω132,concat(map(variables,ravel U))::List Symbol);
-NJ132 := nullSpace(J132)
-
-Yg321 := reindex(reindex(  reindex(Ug*Yg,[3,2,1]),  [2,3,1])*Ωg,[3,1,2]);
-ω321  := reindex(reindex(U,[2,1])*reindex(Yg321,[1,3,2]),[3,2,1])-U*Yg321;
-J321  := jacobian(ravel ω321,concat(map(variables,ravel U))::List Symbol);
-NJ321 := nullSpace(J321)
-
-Yg312 := reindex(reindex(  reindex(Ug*Yg,[3,1,2]),  [2,3,1])*Ωg,[3,1,2]);
-ω312  := reindex(reindex(U,[2,1])*reindex(Yg312,[1,3,2]),[3,2,1])-U*Yg312;
-J312  := jacobian(ravel ω312,concat(map(variables,ravel U))::List Symbol);
-NJ312 := nullSpace(J312)
-
-Yg231 := reindex(reindex(  reindex(Ug*Yg,[2,3,1]),  [2,3,1])*Ωg,[3,1,2]);
-ω231  := reindex(reindex(U,[2,1])*reindex(Yg231,[1,3,2]),[3,2,1])-U*Yg231;
-J231  := jacobian(ravel ω231,concat(map(variables,ravel U))::List Symbol);
-NJ231 := nullSpace(J231)
-\end{axiom}
Ų0:=map(x+->subst(x,[q[0]=-1,q[1]=-1,p[1]=1,p[2]=1,p[3]=1,p[4]=-sqrt(2)]),Ų)$𝐋
Ω0:=map(x+->subst(x,[q[0]=-1,q[1]=-1,p[1]=1,p[2]=1,p[3]=1,p[4]=-sqrt(2)]),Ω)$𝐋
λ0:=map(x+->subst(x,[q[0]=-1,q[1]=-1,p[1]=1,p[2]=1,p[3]=1,p[4]=-sqrt(2)]),λ)$𝐋
\end{axiom}
Quaternion Algebra Is Frobenius In Many Ways
Linear operators over a 4-dimensional vector space representing quaternion algebra
Ref:
- http://arxiv.org/abs/1103.5113
 -permuted Frobenius Algebras
Zbigniew Oziewicz (UNAM), Gregory Peter Wene (UTSA)
- http://mat.uab.es/~kock/TQFT.html
Frobenius algebras and 2D topological quantum field theories
Joachim Kock
- http://en.wikipedia.org/wiki/Frobenius_algebra
We need the Axiom LinearOperator? library.
(1) -> )library MONAL PROP LIN CALEY

   )library cannot find the file LIN.
   Monoidal is now explicitly exposed in frame initial
   Monoidal will be automatically loaded when needed from
      /var/aw/var/LatexWiki/MONAL.NRLIB/MONAL
   Prop is now explicitly exposed in frame initial
   Prop will be automatically loaded when needed from
      /var/aw/var/LatexWiki/PROP.NRLIB/PROP
   CaleyDickson is now explicitly exposed in frame initial
   CaleyDickson will be automatically loaded when needed from
      /var/aw/var/LatexWiki/CALEY.NRLIB/CALEY
Use the following macros for convenient notation
-- summation
macro Σ(x)==reduce(+,x)
macro ΣΞ(x,i)==reduce(+, [x for i in 1..dim])
-- list
macro Ξ(f,i)==[f for i in 1..dim]
𝐋 is the domain of 4-dimensional linear operators over the domain of rational functions ℚ (Expression Integer), i.e. ratio of polynomials with integer coefficients.
dim:=4
 | (1) |
macro ℒ == List
macro ℂ == CaleyDickson
macro ℚ == Expression Integer
𝐋 := LinearOperator(dim,OVAR [], ℚ)
There are no library operations named LinearOperator Use HyperDoc Browse or issue )what op LinearOperator to learn if there is any operation containing " LinearOperator " in its name.
Cannot find a definition or applicable library operation named LinearOperator with argument type(s) PositiveInteger Type Type
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
Now generate structure constants for Quaternion Algebra
The basis consists of the real and imaginary units. We use quaternion multiplication to form the "multiplication table" as a matrix. Then the structure constants can be obtained by dividing each matrix entry by the list of basis vectors.
-- Also split-complex via Caley-Dickson parameter (p0 = -1)
q0:=subscript('q,
 | (2) |
q1:=subscript('q,
 | (3) |
QQ := ℂ(ℂ(ℚ,'i, q0), 'j, q1)
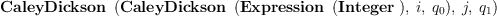 | (4) |
-- Basis: Each B.i is a quaternion number B:ℒ QQ := map(x +-> hyper x,1$SQMATRIX(dim, ℚ)::ℒ ℒ ℚ)
 | (5) |
-- Multiplication table: M:Matrix QQ := matrix Ξ(Ξ(B.i*B.j,i), j)
 | (6) |
-- Function to divide the matrix entries by a basis element
S(y) == map(x +-> real real(x/y),M)
-- The result is a nested list
ѕ :=map(S,B)::ℒ ℒ ℒ ℚ
Compiling function S with type CaleyDickson(CaleyDickson(Expression(
Integer),![\label{eq7}\begin{array}{@{}l}
\displaystyle
\left[{\left[{\left[ 1, \: 0, \: 0, \: 0 \right]}, \:{\left[ 0, \: -{q_{0}}, \: 0, \: 0 \right]}, \:{\left[ 0, \: 0, \: -{q_{1}}, \: 0 \right]}, \:{\left[ 0, \: 0, \: 0, \: -{{q_{0}}\ {q_{1}}}\right]}\right]}, \: \right.
\
\
\displaystyle
\left.{
\begin{array}{@{}l}
\displaystyle
\left[{\left[ 0, \:{\frac{q_{0}}{\overline{q_{0}}}}, \: 0, \: 0 \right]}, \:{\left[{\frac{q_{0}}{\overline{q_{0}}}}, \: 0, \: 0, \: 0 \right]}, \: \right.
\
\
\displaystyle
\left.{\left[ 0, \: 0, \: 0, \: -{\frac{{q_{0}}\ {q_{1}}}{\overline{q_{0}}}}\right]}, \:{\left[ 0, \: 0, \:{\frac{{q_{0}}\ {q_{1}}}{\overline{q_{0}}}}, \: 0 \right]}\right]](images/1022212527695267592-16.0px.png "\label{eq7}\begin{array}{@{}l}
\displaystyle
\left[{\left[{\left[ 1, \: 0, \: 0, \: 0 \right]}, \:{\left[ 0, \: -{q_{0}}, \: 0, \: 0 \right]}, \:{\left[ 0, \: 0, \: -{q_{1}}, \: 0 \right]}, \:{\left[ 0, \: 0, \: 0, \: -{{q_{0}}\ {q_{1}}}\right]}\right]}, \: \right.
\
\
\displaystyle
\left.{
\begin{array}{@{}l}
\displaystyle
\left[{\left[ 0, \:{\frac{q_{0}}{\overline{q_{0}}}}, \: 0, \: 0 \right]}, \:{\left[{\frac{q_{0}}{\overline{q_{0}}}}, \: 0, \: 0, \: 0 \right]}, \: \right.
\
\
\displaystyle
\left.{\left[ 0, \: 0, \: 0, \: -{\frac{{q_{0}}\ {q_{1}}}{\overline{q_{0}}}}\right]}, \:{\left[ 0, \: 0, \:{\frac{{q_{0}}\ {q_{1}}}{\overline{q_{0}}}}, \: 0 \right]}\right]") | (7) |
-- structure constants form a tensor operator Y := ΣΞ(ΣΞ(ΣΞ(ѕ(i)(j)(k)*𝐞.i*𝐝.j*𝐝.k,i), j), k)
There are no library operations named 𝐞 Use HyperDoc Browse or issue )what op 𝐞 to learn if there is any operation containing " 𝐞 " in its name. Cannot find a definition or applicable library operation named 𝐞 with argument type(s) PositiveInteger
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need. FriCAS will attempt to step through and interpret the code. There are no library operations named 𝐞 Use HyperDoc Browse or issue )what op 𝐞 to learn if there is any operation containing " 𝐞 " in its name.
Cannot find a definition or applicable library operation named 𝐞 with argument type(s) PositiveInteger
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
A scalar product is denoted by the (2,0)-tensor

U:=inp([inp([script(u,[[j, i], []]) for i in 1..dim])$𝐋 for j in 1..dim])$𝐋
𝐋 is not a valid type.
Definition 1
We say that the scalar product is associative if the tensor equation holds:
    Y   =   Y
     U     U
In other words, if the (3,0)-tensor:
(2.2,0.1)(2.6,0.1)(2.6,0.9)
\psline[linewidth=0.04cm](2.4,0.3)(2.4,-0.1)
\psbezier[linewidth=0.04](2.4,-0.1)(2.4,-0.9)(3.0,-0.9)(3.0,-0.1)
\psline[linewidth=0.04cm](3.0,-0.1)(3.0,0.9)
\psbezier[linewidth=0.04](4.8,0.9)(4.8,0.1)(4.4,0.1)(4.4,0.9)
\psline[linewidth=0.04cm](4.6,0.3)(4.6,-0.1)
\psbezier[linewidth=0.04](4.6,-0.1)(4.6,-0.9)(4.0,-0.9)(4.0,-0.1)
\psline[linewidth=0.04cm](4.0,-0.1)(4.0,0.9)
\usefont{T1}{ptm}{m}{n}
\rput(3.4948437,0.205){-}
\psline[linewidth=0.04cm](0.6,-0.7)(0.6,0.9)
\psbezier[linewidth=0.04](0.0,-0.1)(0.0,-0.9)(1.2,-0.9)(1.2,-0.1)
\psline[linewidth=0.04cm](0.0,-0.1)(0.0,0.9)
\psline[linewidth=0.04cm](1.2,-0.1)(1.2,0.9)
\usefont{T1}{ptm}{m}{n}
\rput(1.6948438,0.205){=}
\end{pspicture}
}](images/2375189246716000159-16.0px.png "\scalebox{1} % Change this value to rescale the drawing.
{
\begin{pspicture}(0,-0.92)(4.82,0.92)
\psbezier[linewidth=0.04](2.2,0.9)(2.2,0.1)(2.6,0.1)(2.6,0.9)
\psline[linewidth=0.04cm](2.4,0.3)(2.4,-0.1)
\psbezier[linewidth=0.04](2.4,-0.1)(2.4,-0.9)(3.0,-0.9)(3.0,-0.1)
\psline[linewidth=0.04cm](3.0,-0.1)(3.0,0.9)
\psbezier[linewidth=0.04](4.8,0.9)(4.8,0.1)(4.4,0.1)(4.4,0.9)
\psline[linewidth=0.04cm](4.6,0.3)(4.6,-0.1)
\psbezier[linewidth=0.04](4.6,-0.1)(4.6,-0.9)(4.0,-0.9)(4.0,-0.1)
\psline[linewidth=0.04cm](4.0,-0.1)(4.0,0.9)
\usefont{T1}{ptm}{m}{n}
\rput(3.4948437,0.205){-}
\psline[linewidth=0.04cm](0.6,-0.7)(0.6,0.9)
\psbezier[linewidth=0.04](0.0,-0.1)(0.0,-0.9)(1.2,-0.9)(1.2,-0.1)
\psline[linewidth=0.04cm](0.0,-0.1)(0.0,0.9)
\psline[linewidth=0.04cm](1.2,-0.1)(1.2,0.9)
\usefont{T1}{ptm}{m}{n}
\rput(1.6948438,0.205){=}
\end{pspicture}
}") |
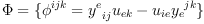 | (8) |
Using the LinearOperator? domain in Axiom and some carefully chosen symbols we can easily enter expressions that are both readable and interpreted by Axiom as "graphical calculus" diagrams describing complex products and compositions of linear operators.
ω:𝐋 :=
     o    Y I      /
     o     U       -
     o    I Y      /
     o     U       o

   𝐋 is not a valid type.
Note: The only purpose of the o symbols on the left above is to serve as a constant left-side margin as required by Axiom. The symbols on the right describe the relation between row.
Definition 2
An algebra with a non-degenerate associative scalar product is called a [Frobenius Algebra]?.
We may consider the problem where multiplication Y is given,
and look for all associative scalar products 
This problem can be solved using linear algebra.
)expose MCALCFN
MultiVariableCalculusFunctions is now explicitly exposed in frame initial J := jacobian(ravel ω,concat map(variables, ravel U)::ℒ Symbol);
There are 1 exposed and 0 unexposed library operations named ravel having 1 argument(s) but none was determined to be applicable. Use HyperDoc Browse,or issue )display op ravel to learn more about the available operations. Perhaps package-calling the operation or using coercions on the arguments will allow you to apply the operation.
Cannot find a definition or applicable library operation named ravel with argument type(s) Variable(ω)
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
The matrix J transforms the coefficients of the tensor  into coefficients of the tensor
 . We are looking for
the general linear family of tensors
 such that
J transforms into  for any such .
If the null space of the J matrix is not empty we can use
the basis to find all non-trivial solutions for U:
Ñ:=nullSpace(J)
There are 3 exposed and 3 unexposed library operations named nullSpace having 1 argument(s) but none was determined to be applicable. Use HyperDoc Browse,or issue )display op nullSpace to learn more about the available operations. Perhaps package-calling the operation or using coercions on the arguments will allow you to apply the operation.
Cannot find a definition or applicable library operation named nullSpace with argument type(s) Variable(J)
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
This defines a family of pre-Frobenius algebras:
test(map(x+->subst(x,ℰ), ω)$𝐋=0*ω)
𝐋 is not a valid type.
The scalar product must be non-degenerate:
Ů:=determinant [[retract((𝐞.i * 𝐞.j)/Ų) for j in 1..dim] for i in 1..dim]
There are no library operations named 𝐞 Use HyperDoc Browse or issue )what op 𝐞 to learn if there is any operation containing " 𝐞 " in its name. Cannot find a definition or applicable library operation named 𝐞 with argument type(s) PositiveInteger
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need. FriCAS will attempt to step through and interpret the code. There are no library operations named 𝐞 Use HyperDoc Browse or issue )what op 𝐞 to learn if there is any operation containing " 𝐞 " in its name.
Cannot find a definition or applicable library operation named 𝐞 with argument type(s) PositiveInteger
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
Definition 3
Co-pairing
Ω:𝐋:=unravel((0/2)$Prop,concat(transpose(1/Ů*adjoint([[retract((𝐞.i * 𝐞.j)/Ų)
  for j in 1..dim] for i in 1..dim]).adjMat)::ℒ ℒ ℚ))

   𝐋 is not a valid type.
Check dimension
d:𝐋:=
    o   Ω    /
    o   Ų    o

   𝐋 is not a valid type.
Definition 4
Co-algebra:
    λ:𝐋 :=
         o    Ω Ω  I    /
         o   I Y I I    /
         o   I  X  I    /
         o   I I  Ų     o
    --test
Why aren't these the same??
λ:𝐋 :=
     o    I Ω     /
     o     Y I    o

   𝐋 is not a valid type.
i = Unit of the algebra
i:=𝐞.1
There are no library operations named 𝐞 Use HyperDoc Browse or issue )what op 𝐞 to learn if there is any operation containing " 𝐞 " in its name.
Cannot find a definition or applicable library operation named 𝐞 with argument type(s) PositiveInteger
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
Definition 5
  i
  U
ι:𝐋:=
    o    i I    /
    o     Ų    o

   𝐋 is not a valid type.
Y=U
ι
test o Y / o ι o = Ų
There are no library operations named o Use HyperDoc Browse or issue )what op o to learn if there is any operation containing " o " in its name.
Cannot find a definition or applicable library operation named o with argument type(s) Variable(Y)
Perhaps you should use "@" to indicate the required return type,or "$" to specify which version of the function you need.
For example:
Ų0:=map(x+->subst(x,[q[0]=-1, q[1]=-1, p[1]=1, p[2]=1, p[3]=1, p[4]=-sqrt(2)]), Ų)$𝐋
𝐋 is not a valid type.